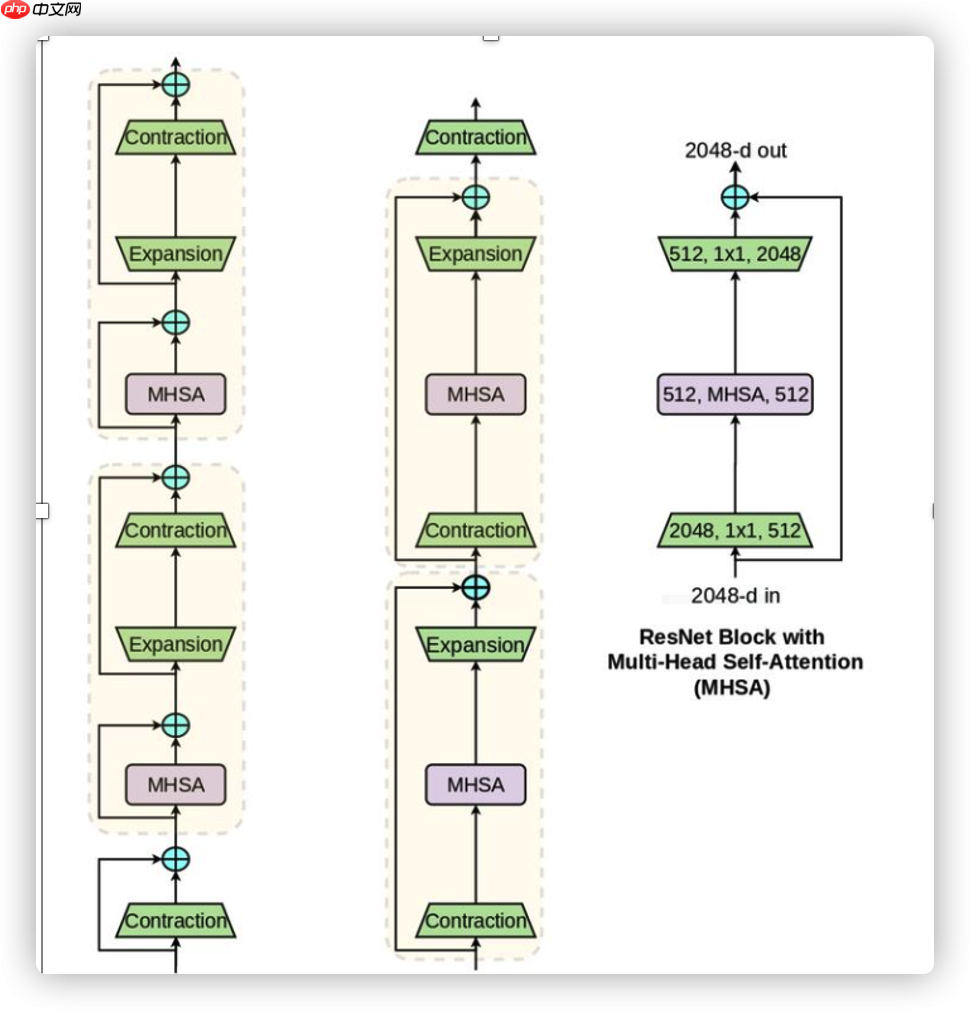
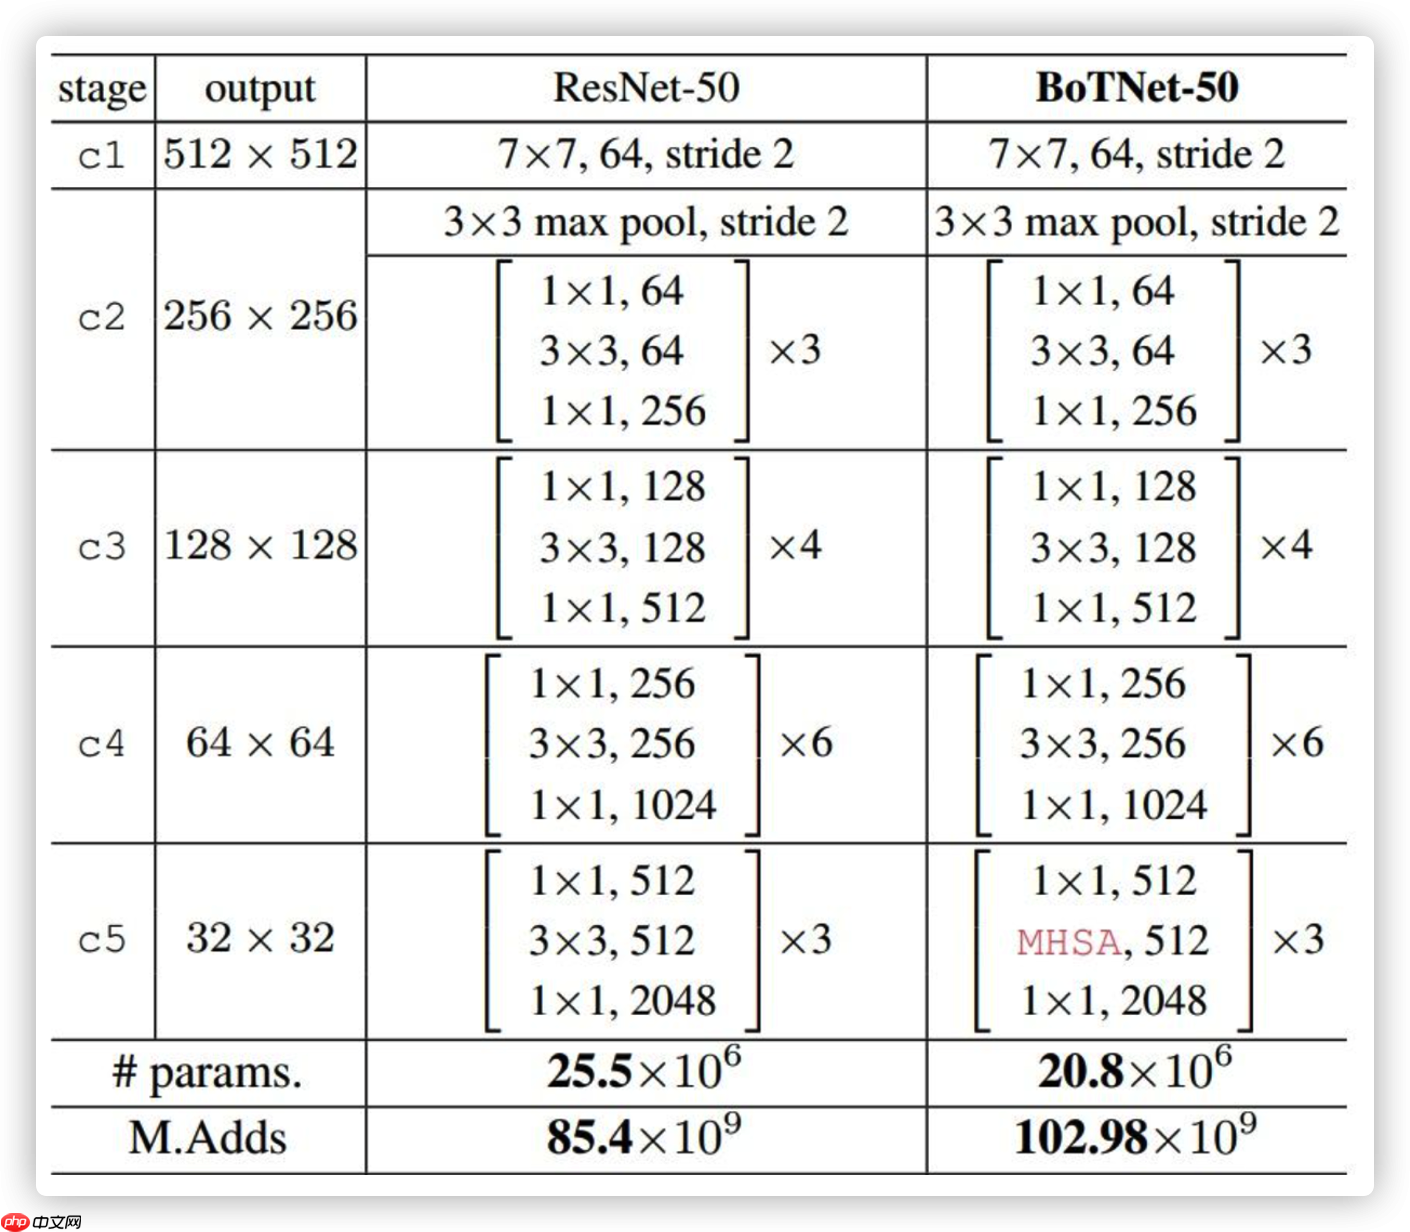
本文围绕声呐图像识别展开,指出现有侧扫声呐人工识别耗时且易误判的问题,介绍用PaddleDetection处理数据集(修改源码适配VOC格式、转换前视声呐数据为COCO格式),并改进YOLO模型(结合PPYOLOV2与YOLO-X解耦头,ResNet加入注意力机制),以提升检测速度与精度。
☞☞☞AI 智能聊天, 问答助手, AI 智能搜索, 免费无限量使用 DeepSeek R1 模型☜☜☜
 Openflow
一键极速绘图,赋能行业工作流
 88
查看详情


<?xml version="1.0" encoding="utf-8"?><annotation>
    <folder>VOC2007</folder>
    <filename>test100.mp4_3380.jpeg</filename>
    <size>
        <width>1280</width>
        <height>720</height>
        <depth>3</depth>
    </size>
    <object>
        <name>gemfield</name>
        <bndbox>
            <xmin>549</xmin>
            <xmax>715</xmax>
            <ymin>257</ymin>
            <ymax>289</ymax>
        </bndbox>
        <truncated>0</truncated>
        <difficult>0</difficult>
    </object>
    <object>
        <name>civilnet</name>
        <bndbox>
            <xmin>842</xmin>
            <xmax>1009</xmax>
            <ymin>138</ymin>
            <ymax>171</ymax>
        </bndbox>
        <truncated>0</truncated>
        <difficult>0</difficult>
    </object>
    <segmented>0</segmented></annotation>
<annotation>
<frame>flv13</frame>
<object>
<name>目标物</name>
<bndbox>
<xmin>165</xmin>
<ymin>4</ymin>
<xmax>402</xmax>
<ymax>422</ymax>
</bndbox>
</object>
<object>
<name>目标物</name>
<bndbox>
<xmin>589</xmin>
<ymin>10</ymin>
<xmax>790</xmax>
<ymax>415</ymax>
</bndbox>
</object></annotation>
if 'h' not in sample:
            sample['h'] = im.shape[0]
        elif sample['h'] != im.shape[0]:
            logger.warning(                "The actual image height: {} is not equal to the "
                "height: {} in annotation, and update sample['h'] by actual "
                "image height.".format(im.shape[0], sample['h']))
            sample['h'] = im.shape[0]
sample['h'] = im.shape[0]
<?xml version='1.0' encoding='UTF-8'?><annotation>
    <sonar>
        <type>Tritech 1200ik</type>
        <version>1</version>
        <range>15.0003</range>
        <horiangle>120</horiangle>
        <vertiangle>20</vertiangle>
        <soundspeed>1474.3</soundspeed>
        <frequency>720k </frequency>
    </sonar>
    <folder>log_2025-03-15-104935annotaion</folder>
    <filename>log_2025-03-15-104935_annotaion_14.xml</filename>
    <path>/Users/kim_shally/Desktop/sonar_annotation/20250315/Ball_SquareCage_Tyre/log_2025-03-15-104935_annotaion/log_2025-03-15-104935_annotaion_14.bmp</path>
    <size>
        <width>512</width>
        <height>1840</height>
        <depth>3</depth>
    </size>
    <object>
        <name>ball</name>
        <bndbox>
            <xmin>399</xmin>
            <ymin>1307</ymin>
            <xmax>447</xmax>
            <ymax>1399</ymax>
        </bndbox>
    </object>
    <object>
        <name>square cage</name>
        <bndbox>
            <xmin>182</xmin>
            <ymin>1413</ymin>
            <xmax>239</xmax>
            <ymax>1525</ymax>
        </bndbox>
    </object></annotation>
#!/usr/bin/python# pip install lxmlimport sysimport osimport jsonimport xml.etree.ElementTree as ETimport glob

START_BOUNDING_BOX_ID = 1PRE_DEFINE_CATEGORIES = None# If necessary, pre-define category and its id#  PRE_DEFINE_CATEGORIES = {"aeroplane": 1, "bicycle": 2, "bird": 3, "boat": 4,#  "bottle":5, "bus": 6, "car": 7, "cat": 8, "chair": 9,#  "cow": 10, "diningtable": 11, "dog": 12, "horse": 13,#  "motorbike": 14, "person": 15, "pottedplant": 16,#  "sheep": 17, "sofa": 18, "train": 19, "tvmonitor": 20}def get(root, name):
    vars = root.findall(name)    return varsdef get_and_check(root, name, length):
    vars = root.findall(name)    if len(vars) == 0:        raise ValueError("Can not find %s in %s." % (name, root.tag))    if length > 0 and len(vars) != length:        raise ValueError(            "The size of %s is supposed to be %d, but is %d."
            % (name, length, len(vars))
        )    if length == 1:        vars = vars[0]    return varsdef get_filename_as_int(filename):
    try:
        filename = filename.replace("\", "/")
        filename = os.path.splitext(os.path.basename(filename))[0]        return int(filename)    except:        raise ValueError("Filename %s is supposed to be an integer." % (filename))def get_categories(xml_files):
    """Generate category name to id mapping from a list of xml files.

    Arguments:
        xml_files {list} -- A list of xml file paths.

    Returns:
        dict -- category name to id mapping.
    """
    classes_names = []    for xml_file in xml_files:
        tree = ET.parse(xml_file)
        root = tree.getroot()        for member in root.findall("object"):
            classes_names.append(member[0].text)
    classes_names = list(set(classes_names))
    classes_names.sort()    return {name: i for i, name in enumerate(classes_names)}def convert(xml_files, json_file):
    json_dict = {"images": [], "type": "instances", "annotations": [], "categories": []}    if PRE_DEFINE_CATEGORIES is not None:
        categories = PRE_DEFINE_CATEGORIES    else:
        categories = get_categories(xml_files)
    bnd_id = START_BOUNDING_BOX_ID    for xml_file in xml_files:
        tree = ET.parse(xml_file)
        root = tree.getroot()
        path = get(root, "path")        if len(path) == 1:
            filename = os.path.basename(path[0].text)        elif len(path) == 0:
            filename = get_and_check(root, "filename", 1).text        else:            raise ValueError("%d paths found in %s" % (len(path), xml_file))        ## The filename must be a number
        image_id = get_filename_as_int(filename)
        size = get_and_check(root, "size", 1)
        width = int(get_and_check(size, "width", 1).text)
        height = int(get_and_check(size, "height", 1).text)
        image = {            "file_name": filename,            "height": height,            "width": width,            "id": image_id,
        }
        json_dict["images"].append(image)        ## Currently we do not support segmentation.
        #  segmented = get_and_check(root, 'segmented', 1).text
        #  assert segmented == '0'
        for obj in get(root, "object"):
            category = get_and_check(obj, "name", 1).text            if category not in categories:
                new_id = len(categories)
                categories[category] = new_id
            category_id = categories[category]
            bndbox = get_and_check(obj, "bndbox", 1)
            xmin = int(get_and_check(bndbox, "xmin", 1).text) - 1
            ymin = int(get_and_check(bndbox, "ymin", 1).text) - 1
            xmax = int(get_and_check(bndbox, "xmax", 1).text)
            ymax = int(get_and_check(bndbox, "ymax", 1).text)            assert xmax > xmin            assert ymax > ymin
            o_width = abs(xmax - xmin)
            o_height = abs(ymax - ymin)
            ann = {                "area": o_width * o_height,                "iscrowd": 0,                "image_id": image_id,                "bbox": [xmin, ymin, o_width, o_height],                "category_id": category_id,                "id": bnd_id,                "ignore": 0,                "segmentation": [],
            }
            json_dict["annotations"].append(ann)
            bnd_id = bnd_id + 1

    for cate, cid in categories.items():
        cat = {"supercategory": "none", "id": cid, "name": cate}
        json_dict["categories"].append(cat)

    os.makedirs(os.path.dirname(json_file), exist_ok=True)
    json_fp = open(json_file, "w")
    json_str = json.dumps(json_dict)
    json_fp.write(json_str)
    json_fp.close()if __name__ == "__main__":    import argparse

    parser = argparse.ArgumentParser(
        description="Convert Pascal VOC annotation to COCO format."
    )
    parser.add_argument("xml_dir", help="Directory path to xml files.", type=str)
    parser.add_argument("json_file", help="Output COCO format json file.", type=str)
    args = parser.parse_args()
    xml_files = glob.glob(os.path.join(args.xml_dir, "*.xml"))    # If you want to do train/test split, you can pass a subset of xml files to convert function.
    print("Number of xml files: {}".format(len(xml_files)))
    convert(xml_files, args.json_file)    print("Success: {}".format(args.json_file))


# Copyright (c) 2025 PaddlePaddle Authors. All Rights Reserved. # # Licensed under the Apache License, Version 2.0 (the "License"); # you may not use this file except in compliance with the License. # You may obtain a copy of the License at # # http://www.apache.org/licenses/LICENSE-2.0 # # Unless required by applicable law or agreed to in writing, software # distributed under the License is distributed on an "AS IS" BASIS, # WITHOUT WARRANTIES OR CONDITIONS OF ANY KIND, either express or implied. # See the License for the specific language governing permissions and # limitations under the License.import mathfrom numbers import Integralimport paddleimport paddle.nn as nnimport paddle.nn.functional as Ffrom ppdet.core.workspace import register, serializablefrom paddle.regularizer import L2Decayfrom paddle.nn.initializer import Uniformfrom paddle import ParamAttrfrom paddle.nn.initializer import Constantfrom paddle.vision.ops import DeformConv2Dfrom .name_adapter import NameAdapterfrom ..shape_spec import ShapeSpecimport numpy as np# from paddle.nn import Conv2D, MaxPool2D, BatchNorm, Linearfrom paddle.nn import Conv2D, MaxPool2D, BatchNorm2D, Linear ,ReLUfrom einops import rearrange
__all__ = ['ResNet', 'Res5Head', 'Blocks', 'BasicBlock', 'BottleNeck']
ResNet_cfg = { 18: [2, 2, 2, 2], 34: [3, 4, 6, 3], 50: [3, 4, 6, 3], 101: [3, 4, 23, 3], 152: [3, 8, 36, 3],
}def get_n_params(model):
pp=0
for p in list(model.parameters()):
nn=1
for s in list(p.size()):
nn = nn*s
pp += nn return ppclass MHSA(paddle.nn.Layer):
def __init__(self, n_dims, width=38, height=38, heads=4):
super(MHSA, self).__init__()
self.heads = heads
self.query = Conv2D(512, 512, kernel_size=1)
self.key = Conv2D(512, 512, kernel_size=1)
self.value = Conv2D(n_dims, n_dims, kernel_size=1)
self.create_parameter([1,1])
self.rel_h = self.create_parameter(shape=[1,heads,n_dims // heads,1,height],default_initializer=paddle.nn.initializer.Normal(std=1e-4),dtype='float32') #[1,4,128,1,38]
self.add_parameter('rel_h',self.rel_h)
self.rel_w = self.create_parameter(shape=[1, heads, n_dims // heads, width, 1],default_initializer=paddle.nn.initializer.Normal(std=1e-4),dtype='float32')# [1,4,128,38,1]
self.add_parameter('rel_w',self.rel_w) def forward(self, x):
n_batch, C, width, height = x.shape
q = self.query(x).reshape([n_batch, self.heads, C // self.heads, -1])#(1,4,128,1444)
k = self.key(x).reshape([n_batch, self.heads, C // self.heads, -1])#(1 ,4 ,128 ,1444)
v = self.value(x).reshape([n_batch, self.heads, C // self.heads, -1])#(1,4,128,1444)
content_content = paddle.matmul(paddle.transpose(q,(0, 1, 3, 2)), k) # (1,4,1444,1444)
content_position = paddle.transpose((self.rel_h + self.rel_w).reshape([1, self.heads, C // self.heads, -1]),[0, 1, 3, 2])
content_position = paddle.matmul(content_position, q)
energy = content_content + content_position
attention = paddle.nn.functional.softmax(energy)
out = paddle.matmul(v, attention)
out = paddle.reshape(out,[n_batch, C, width, height]) # [1,512,38,38]
return outclass ConvNormLayer(nn.Layer):
def __init__(self,
ch_in,
ch_out,
filter_size,
stride,
groups=1,
act=None,
norm_type='bn',
norm_decay=0.,
freeze_norm=True,
lr=1.0,
dcn_v2=False):
super(ConvNormLayer, self).__init__() assert norm_type in ['bn', 'sync_bn']
self.norm_type = norm_type
self.act = act
self.dcn_v2 = dcn_v2 if not self.dcn_v2:
self.conv = nn.Conv2D(
in_channels=ch_in,
out_channels=ch_out,
kernel_size=filter_size,
stride=stride,
padding=(filter_size - 1) // 2,
groups=groups,
weight_attr=ParamAttr(learning_rate=lr),
bias_attr=False) else:
self.offset_channel = 2 * filter_size**2
self.mask_channel = filter_size**2
self.conv_offset = nn.Conv2D(
in_channels=ch_in,
out_channels=3 * filter_size**2,
kernel_size=filter_size,
stride=stride,
padding=(filter_size - 1) // 2,
weight_attr=ParamAttr(initializer=Constant(0.)),
bias_attr=ParamAttr(initializer=Constant(0.)))
self.conv = DeformConv2D(
in_channels=ch_in,
out_channels=ch_out,
kernel_size=filter_size,
stride=stride,
padding=(filter_size - 1) // 2,
dilation=1,
groups=groups,
weight_attr=ParamAttr(learning_rate=lr),
bias_attr=False)
norm_lr = 0. if freeze_norm else lr
param_attr = ParamAttr(
learning_rate=norm_lr,
regularizer=L2Decay(norm_decay),
trainable=False if freeze_norm else True)
bias_attr = ParamAttr(
learning_rate=norm_lr,
regularizer=L2Decay(norm_decay),
trainable=False if freeze_norm else True)
global_stats = True if freeze_norm else False
if norm_type == 'sync_bn':
self.norm = nn.SyncBatchNorm(
ch_out, weight_attr=param_attr, bias_attr=bias_attr) else:
self.norm = nn.BatchNorm(
ch_out,
act=None,
param_attr=param_attr,
bias_attr=bias_attr,
use_global_stats=global_stats)
norm_params = self.norm.parameters() if freeze_norm: for param in norm_params:
param.stop_gradient = True
def forward(self, inputs):
if not self.dcn_v2:
out = self.conv(inputs) else:
offset_mask = self.conv_offset(inputs)
offset, mask = paddle.split(
offset_mask,
num_or_sections=[self.offset_channel, self.mask_channel],
axis=1)
mask = F.sigmoid(mask)
out = self.conv(inputs, offset, mask=mask) if self.norm_type in ['bn', 'sync_bn']:
out = self.norm(out) if self.act:
out = getattr(F, self.act)(out) return outclass SELayer(nn.Layer):
def __init__(self, ch, reduction_ratio=16):
super(SELayer, self).__init__()
self.pool = nn.AdaptiveAvgPool2D(1)
stdv = 1.0 / math.sqrt(ch)
c_ = ch // reduction_ratio
self.squeeze = nn.Linear(
ch,
c_,
weight_attr=paddle.ParamAttr(initializer=Uniform(-stdv, stdv)),
bias_attr=True)
stdv = 1.0 / math.sqrt(c_)
self.extract = nn.Linear(
c_,
ch,
weight_attr=paddle.ParamAttr(initializer=Uniform(-stdv, stdv)),
bias_attr=True) def forward(self, inputs):
out = self.pool(inputs)
out = paddle.squeeze(out, axis=[2, 3])
out = self.squeeze(out)
out = F.relu(out)
out = self.extract(out)
out = F.sigmoid(out)
out = paddle.unsqueeze(out, axis=[2, 3])
scale = out * inputs return scaleclass BasicBlock(nn.Layer):
expansion = 1
def __init__(self,
ch_in,
ch_out,
stride,
shortcut,
variant='b',
groups=1,
base_width=64,
lr=1.0,
norm_type='bn',
norm_decay=0.,
freeze_norm=True,
dcn_v2=False,
std_senet=False):
super(BasicBlock, self).__init__() assert dcn_v2 is False, "Not implemented yet."
assert groups == 1 and base_width == 64, 'BasicBlock only supports groups=1 and base_width=64'
self.shortcut = shortcut if not shortcut: if variant == 'd' and stride == 2:
self.short = nn.Sequential()
self.short.add_sublayer( 'pool',
nn.AvgPool2D(
kernel_size=2, stride=2, padding=0, ceil_mode=True))
self.short.add_sublayer( 'conv',
ConvNormLayer(
ch_in=ch_in,
ch_out=ch_out,
filter_size=1,
stride=1,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr)) else:
self.short = ConvNormLayer(
ch_in=ch_in,
ch_out=ch_out,
filter_size=1,
stride=stride,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr)
self.branch2a = ConvNormLayer(
ch_in=ch_in,
ch_out=ch_out,
filter_size=3,
stride=stride,
act='relu',
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr)
self.branch2b = ConvNormLayer(
ch_in=ch_out,
ch_out=ch_out,
filter_size=3,
stride=1,
act=None,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr)
self.std_senet = std_senet if self.std_senet:
self.se = SELayer(ch_out) def forward(self, inputs):
out = self.branch2a(inputs)
out = self.branch2b(out) if self.std_senet:
out = self.se(out) if self.shortcut:
short = inputs else:
short = self.short(inputs)
out = paddle.add(x=out, y=short)
out = F.relu(out) return outclass BottleNeck(nn.Layer):
expansion = 4
def __init__(self,
x,
y,
ch_in, # 1024
ch_out, #512
stride, #
shortcut,
variant='b',
groups=1,
base_width=4,
lr=1.0,
norm_type='bn',
norm_decay=0.,
freeze_norm=True,
dcn_v2=False,
std_senet=False):
super(BottleNeck, self).__init__() if variant == 'a':
stride1, stride2 = stride, 1
else:
stride1, stride2 = 1, stride # ResNeXt
width = int(ch_out * (base_width / 64.)) * groups
self.shortcut = shortcut if not shortcut: if variant == 'd' and stride == 2:
self.short = nn.Sequential()
self.short.add_sublayer( 'pool',
nn.AvgPool2D(
kernel_size=2, stride=2, padding=0, ceil_mode=True))
self.short.add_sublayer( 'conv',
ConvNormLayer(
ch_in=ch_in,
ch_out=ch_out * self.expansion,
filter_size=1,
stride=1,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr)) else:
self.short = ConvNormLayer(
ch_in=ch_in,
ch_out=ch_out * self.expansion,
filter_size=1,
stride=stride,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr)
self.branch2a = ConvNormLayer(
ch_in=ch_in,
ch_out=width,
filter_size=1,
stride=stride1,
groups=1,
act='relu',
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr)
if x and y:
self.branch2b = paddle.nn.LayerList()
self.branch2b.append(MHSA(512, width=int(48), height=int(48), heads=4))
self.branch2b.append(paddle.nn.AvgPool2D(2, 2))
self.branch2b = paddle.nn.Sequential(*self.branch2b) elif x and not y:
self.branch2b = MHSA(512,width=24, height=24) else:
self.branch2b = ConvNormLayer(
ch_in=width,
ch_out=width,
filter_size=3,
stride=stride2,
groups=groups,
act='relu',
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr,
dcn_v2=dcn_v2)
self.branch2c = ConvNormLayer(
ch_in=width,
ch_out=ch_out * self.expansion,
filter_size=1,
stride=1,
groups=1,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr)
self.std_senet = std_senet if self.std_senet:
self.se = SELayer(ch_out * self.expansion) def forward(self, inputs):
out = self.branch2a(inputs)
out = self.branch2b(out)
out = self.branch2c(out) if self.std_senet:
out = self.se(out) if self.shortcut:
short = inputs else:
short = self.short(inputs)
out = paddle.add(x=out, y=short)
out = F.relu(out) return outclass Blocks(nn.Layer):
def __init__(self,
block,
x,
ch_in,
ch_out,
count,
name_adapter,
stage_num,
variant='b',
groups=1,
base_width=64,
lr=1.0,
norm_type='bn',
norm_decay=0.,
freeze_norm=True,
dcn_v2=False,
std_senet=False):
super(Blocks, self).__init__()
self.blocks = [] for i in range(count): if i == 0:
y = 1
else:
y = 0
conv_name = name_adapter.fix_layer_warp_name(stage_num, count, i)
layer = self.add_sublayer(
conv_name,
block(
x,
y,
ch_in=ch_in,
ch_out=ch_out,
stride=2 if i == 0 and stage_num != 2 else 1,
shortcut=False if i == 0 else True,
variant=variant,
groups=groups,
base_width=base_width,
lr=lr,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
dcn_v2=dcn_v2,
std_senet=std_senet))
self.blocks.append(layer) if i == 0:
ch_in = ch_out * block.expansion def forward(self, inputs):
block_out = inputs for block in self.blocks:
block_out = block(block_out) return block_out@register@serializableclass ResNet(nn.Layer):
__shared__ = ['norm_type'] def __init__(self,
depth=50,
ch_in=64,
variant='b',
lr_mult_list=[1.0, 1.0, 1.0, 1.0],
groups=1,
base_width=64,
norm_type='bn',
norm_decay=0,
freeze_norm=True,
freeze_at=0,
return_idx=[0, 1, 2, 3],
dcn_v2_stages=[-1], # [3]
num_stages=4,
std_senet=False):
"""
Residual Network, see https://arxiv.org/abs/1512.03385
Args:
depth (int): ResNet depth, should be 18, 34, 50, 101, 152.
ch_in (int): output channel of first stage, default 64
variant (str): ResNet variant, supports 'a', 'b', 'c', 'd' currently
lr_mult_list (list): learning rate ratio of different resnet stages(2,3,4,5),
lower learning rate ratio is need for pretrained model
got using distillation(default as [1.0, 1.0, 1.0, 1.0]).
groups (int): group convolution cardinality
base_width (int): base width of each group convolution
norm_type (str): normalization type, 'bn', 'sync_bn' or 'affine_channel'
norm_decay (float): weight decay for normalization layer weights
freeze_norm (bool): freeze normalization layers
freeze_at (int): freeze the backbone at which stage
return_idx (list): index of the stages whose feature maps are returned
dcn_v2_stages (list): index of stages who select deformable conv v2
num_stages (int): total num of stages
std_senet (bool): whether use senet, default True
"""
super(ResNet, self).__init__()
self._model_type = 'ResNet' if groups == 1 else 'ResNeXt'
assert num_stages >= 1 and num_stages <= 4
self.depth = depth
self.variant = variant
self.groups = groups
self.base_width = base_width
self.norm_type = norm_type
self.norm_decay = norm_decay
self.freeze_norm = freeze_norm
self.freeze_at = freeze_at if isinstance(return_idx, Integral):
return_idx = [return_idx] assert max(return_idx) < num_stages, 'the maximum return index must smaller than num_stages, ' 'but received maximum return index is {} and num_stages ' 'is {}'.format(max(return_idx), num_stages)
self.return_idx = return_idx
self.num_stages = num_stages assert len(lr_mult_list) == 4, "lr_mult_list length must be 4 but got {}".format(len(lr_mult_list)) if isinstance(dcn_v2_stages, Integral):
dcn_v2_stages = [dcn_v2_stages] assert max(dcn_v2_stages) < num_stages if isinstance(dcn_v2_stages, Integral):
dcn_v2_stages = [dcn_v2_stages] assert max(dcn_v2_stages) < num_stages
self.dcn_v2_stages = dcn_v2_stages
block_nums = ResNet_cfg[depth]
na = NameAdapter(self)
conv1_name = na.fix_c1_stage_name() if variant in ['c', 'd']:
conv_def = [
[3, ch_in // 2, 3, 2, "conv1_1"],
[ch_in // 2, ch_in // 2, 3, 1, "conv1_2"],
[ch_in // 2, ch_in, 3, 1, "conv1_3"],
] else:
conv_def = [[3, ch_in, 7, 2, conv1_name]]
self.conv1 = nn.Sequential() for (c_in, c_out, k, s, _name) in conv_def:
self.conv1.add_sublayer(
_name,
ConvNormLayer(
ch_in=c_in,
ch_out=c_out,
filter_size=k,
stride=s,
groups=1,
act='relu',
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=1.0))
self.ch_in = ch_in
ch_out_list = [64, 128, 256, 512]
block = BottleNeck if depth >= 50 else BasicBlock
self._out_channels = [block.expansion * v for v in ch_out_list]
self._out_strides = [4, 8, 16, 32]
self.res_layers = [] for i in range(num_stages): if i == 3 :
x = 1
else :
x = 0
lr_mult = lr_mult_list[i]
stage_num = i + 2
res_name = "res{}".format(stage_num)
res_layer = self.add_sublayer(
res_name,
Blocks(
block,
x,
self.ch_in,
ch_out_list[i],
count=block_nums[i],
name_adapter=na,
stage_num=stage_num,
variant=variant,
groups=groups,
base_width=base_width,
lr=lr_mult,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
dcn_v2=(i in self.dcn_v2_stages),
std_senet=std_senet))
self.res_layers.append(res_layer)
self.ch_in = self._out_channels[i] @property
def out_shape(self):
return [
ShapeSpec(
channels=self._out_channels[i], stride=self._out_strides[i]) for i in self.return_idx
] def forward(self, inputs):
x = inputs['image']
conv1 = self.conv1(x)
x = F.max_pool2d(conv1, kernel_size=3, stride=2, padding=1)
outs = [] for idx, stage in enumerate(self.res_layers):
x = stage(x) if idx == self.freeze_at:
x.stop_gradient = True
if idx in self.return_idx:
outs.append(x) return outs@registerclass Res5Head(nn.Layer):
def __init__(self, depth=50):
super(Res5Head, self).__init__()
feat_in, feat_out = [1024, 512] if depth < 50:
feat_in = 256
na = NameAdapter(self)
block = BottleNeck if depth >= 50 else BasicBlock
self.res5 = Blocks(
block, feat_in, feat_out, count=3, name_adapter=na, stage_num=5)
self.feat_out = feat_out if depth < 50 else feat_out * 4 @property
def out_shape(self):
return [ShapeSpec(
channels=self.feat_out,
stride=16, )] def forward(self, roi_feat, stage=0):
y = self.res5(roi_feat) return y
# Copyright (c) 2025 PaddlePaddle Authors. All Rights Reserved. # # Licensed under the Apache License, Version 2.0 (the "License"); # you may not use this file except in compliance with the License. # You may obtain a copy of the License at # # http://www.apache.org/licenses/LICENSE-2.0 # # Unless required by applicable law or agreed to in writing, software # distributed under the License is distributed on an "AS IS" BASIS, # WITHOUT WARRANTIES OR CONDITIONS OF ANY KIND, either express or implied. # See the License for the specific language governing permissions and # limitations under the License.from cgitb import resetimport mathfrom numbers import Integralimport cv2import paddleimport paddle.nn as nnimport paddle.nn.functional as Ffrom ppdet.core.workspace import register, serializablefrom paddle.regularizer import L2Decayfrom paddle.nn.initializer import Uniformfrom paddle import ParamAttrfrom paddle.nn.initializer import Constantfrom paddle.vision.ops import DeformConv2Dfrom .name_adapter import NameAdapterfrom ..shape_spec import ShapeSpecimport numpy as np# from paddle.nn import Conv2D, MaxPool2D, BatchNorm, Linearfrom paddle.nn import Conv2D, MaxPool2D, BatchNorm2D, Linear ,ReLUfrom einops import rearrange
__all__ = ['BotNet', 'Bot5Head', 'Blocks', 'BasicBlock', 'BottleNeck']
ResNet_cfg = { 18: [2, 2, 2, 2], 34: [3, 4, 6, 3], 50: [3, 4, 6, 3], 101: [3, 4, 23, 3], 152: [3, 8, 36, 3],
}def expand_dim(t, dim, k):
"""
Expand dims for t at dim to k
"""
t = t.unsqueeze(axis=dim)
expand_shape = [-1] * len(t.shape)
expand_shape[dim] = k return paddle.expand(t, expand_shape)def rel_to_abs(x):
"""
x: [B, Nh * H, L, 2L - 1]
Convert relative position between the key and query to their absolute position respectively.
"""
B, Nh, L, _ = x.shape # pad to shift from relative to absolute indexing
col_pad = paddle.zeros([B, Nh, L, 1])
x = paddle.concat([x, col_pad], axis=3)
flat_x = x.reshape([B, Nh, L * 2 * L])
flat_pad = paddle.zeros([B, Nh, L - 1])
flat_x = paddle.concat([flat_x, flat_pad], axis=2) # Reshape and slice out the padded elements
final_x = flat_x.reshape([B, Nh, L + 1, 2 * L - 1]) return final_x[:, :, :L, L - 1 :]def relative_logits_1d(q, rel_k):
"""
q: [B, Nh, H, W, d]
rel_k: [2W - 1, d]
Computes relative logits along one dimension.
"""
B, Nh, H, W, _ = q.shape
rel_logits = paddle.matmul(q, rel_k.transpose((1,0))) # Collapse height and heads
rel_logits = rel_logits.reshape([-1, Nh * H, W, 2 * W - 1])
rel_logits = rel_to_abs(rel_logits)
rel_logits = rel_logits.reshape([-1, Nh, H, W, W])
rel_logits = expand_dim(rel_logits, dim=3, k=H) return rel_logitsclass RelPosEmb(nn.Layer):
'''Relative position encoding'''
def __init__(self,
height,
width,
dim_head):
super().__init__()
scale = dim_head ** -0.5
self.height = height
self.width = width
h_shape = [height * 2 - 1, dim_head]
w_shape = [width * 2 - 1, dim_head]
self.rel_height = paddle.create_parameter(
shape=h_shape, dtype='float32',
default_initializer=paddle.nn.initializer.Assign(paddle.randn(h_shape)*scale)
)
self.rel_width = paddle.create_parameter(
shape=w_shape, dtype='float32',
default_initializer=paddle.nn.initializer.Assign(paddle.randn(w_shape)*scale)
) def forward(self, q):
H = self.height
W = self.width
B, N, _, D = q.shape
q = q.reshape([B, N, H, W, D]) # "B N (H W) D -> B N H W D"
rel_logits_w = relative_logits_1d(q, self.rel_width)
rel_logits_w = rel_logits_w.transpose(perm=[0, 1, 2, 4, 3, 5])
B, N, X, I, Y, J = rel_logits_w.shape
rel_logits_w = rel_logits_w.reshape([B, N, X*Y, I*J]) # "B N X I Y J-> B N (X Y) (I J)"
q = q.transpose(perm=[0, 1, 3, 2, 4]) # "B N H W D -> B N W H D"
rel_logits_h = relative_logits_1d(q, self.rel_height)
rel_logits_h = rel_logits_h.transpose(perm=[0, 1, 4, 2, 5, 3])
B, N, X, I, Y, J = rel_logits_h.shape
rel_logits_h = rel_logits_h.reshape([B, N, Y*X, J*I]) # "B N X I Y J -> B N (Y X) (J I)"
return rel_logits_w + rel_logits_hclass MHSA(nn.Layer):
'''Multi-Head Self-Attention'''
def __init__(self,
dim,
fmap_size,
heads=4,
dim_qk=128,
dim_v=128):
"""
dim: number of channels of feature map
fmap_size: [H, W]
dim_qk: vector dimension for q, k
dim_v: vector dimension for v (not necessarily the same with q, k)
"""
super().__init__()
self.scale = dim_qk ** -0.5
self.heads = heads
out_channels_qk = heads * dim_qk
out_channels_v = heads * dim_v
self.to_qk = nn.Conv2D(dim, out_channels_qk * 2, 1, bias_attr=False)
self.to_v = nn.Conv2D(dim, out_channels_v, 1, bias_attr=False)
self.softmax = nn.Softmax(axis=-1)
height, width = fmap_size
self.pos_emb = RelPosEmb(height, width, dim_qk) def transpose_multihead(self, x):
B, N, H, W = x.shape
x = x.reshape([B, self.heads, -1, H, W]) # "B (h D) H W -> B h D H W"
x = x.transpose(perm=[0, 1, 3, 4, 2]) # "B h D H W -> B h H W D"
x = x.reshape([B, self.heads, H*W, -1]) # "B h H W D -> B h (H W) D"
return x def forward(self, featuremap):
"""
featuremap: [B, d_in, H, W]
Output: [B, H, W, head * d_v]
"""
B, C, H, W = featuremap.shape
q, k = self.to_qk(featuremap).chunk(2, axis=1)
v = self.to_v(featuremap)
q, k, v = map(self.transpose_multihead, [q, k, v])
q *= self.scale
logits = paddle.matmul(q, k.transpose(perm=[0, 1, 3, 2]))
logits += self.pos_emb(q)
weights = self.softmax(logits)
attn_out = paddle.matmul(weights, v)
a_B, a_N, a_, a_D = attn_out.shape
attn_out = attn_out.reshape([a_B, a_N, H, -1, a_D]) # "B N (H W) D -> B N H W D"
attn_out = attn_out.transpose(perm=[0, 1, 4, 2, 3]) # "B N H W D -> B N D H W"
attn_out = attn_out.reshape([a_B, a_N*a_D, H, -1]) # "B N D H W -> B (N D) H W"
return attn_outclass ConvNormLayer(nn.Layer):
def __init__(self,
ch_in,
ch_out,
filter_size,
stride,
groups=1,
act=None,
norm_type='bn',
norm_decay=0.,
freeze_norm=True,
lr=1.0,
dcn_v2=False):
super(ConvNormLayer, self).__init__() assert norm_type in ['bn', 'sync_bn']
self.norm_type = norm_type
self.act = act
self.dcn_v2 = dcn_v2 if not self.dcn_v2:
self.conv = nn.Conv2D(
in_channels=ch_in,
out_channels=ch_out,
kernel_size=filter_size,
stride=stride,
padding=(filter_size - 1) // 2,
groups=groups,
weight_attr=ParamAttr(learning_rate=lr),
bias_attr=False) else:
self.offset_channel = 2 * filter_size**2
self.mask_channel = filter_size**2
self.conv_offset = nn.Conv2D(
in_channels=ch_in,
out_channels=3 * filter_size**2,
kernel_size=filter_size,
stride=stride,
padding=(filter_size - 1) // 2,
weight_attr=ParamAttr(initializer=Constant(0.)),
bias_attr=ParamAttr(initializer=Constant(0.)))
self.conv = DeformConv2D(
in_channels=ch_in,
out_channels=ch_out,
kernel_size=filter_size,
stride=stride,
padding=(filter_size - 1) // 2,
dilation=1,
groups=groups,
weight_attr=ParamAttr(learning_rate=lr),
bias_attr=False)
norm_lr = 0. if freeze_norm else lr
param_attr = ParamAttr(
learning_rate=norm_lr,
regularizer=L2Decay(norm_decay),
trainable=False if freeze_norm else True)
bias_attr = ParamAttr(
learning_rate=norm_lr,
regularizer=L2Decay(norm_decay),
trainable=False if freeze_norm else True)
global_stats = True if freeze_norm else False
if norm_type == 'sync_bn':
self.norm = nn.SyncBatchNorm(
ch_out, weight_attr=param_attr, bias_attr=bias_attr) else:
self.norm = nn.BatchNorm(
ch_out,
act=None,
param_attr=param_attr,
bias_attr=bias_attr,
use_global_stats=global_stats)
norm_params = self.norm.parameters() if freeze_norm: for param in norm_params:
param.stop_gradient = True
def forward(self, inputs):
if not self.dcn_v2:
out = self.conv(inputs) else:
offset_mask = self.conv_offset(inputs)
offset, mask = paddle.split(
offset_mask,
num_or_sections=[self.offset_channel, self.mask_channel],
axis=1)
mask = F.sigmoid(mask)
out = self.conv(inputs, offset, mask=mask) if self.norm_type in ['bn', 'sync_bn']:
out = self.norm(out) if self.act:
out = getattr(F, self.act)(out) return outclass SELayer(nn.Layer):
def __init__(self, ch, reduction_ratio=16):
super(SELayer, self).__init__()
self.pool = nn.AdaptiveAvgPool2D(1)
stdv = 1.0 / math.sqrt(ch)
c_ = ch // reduction_ratio
self.squeeze = nn.Linear(
ch,
c_,
weight_attr=paddle.ParamAttr(initializer=Uniform(-stdv, stdv)),
bias_attr=True)
stdv = 1.0 / math.sqrt(c_)
self.extract = nn.Linear(
c_,
ch,
weight_attr=paddle.ParamAttr(initializer=Uniform(-stdv, stdv)),
bias_attr=True) def forward(self, inputs):
out = self.pool(inputs)
out = paddle.squeeze(out, axis=[2, 3])
out = self.squeeze(out)
out = F.relu(out)
out = self.extract(out)
out = F.sigmoid(out)
out = paddle.unsqueeze(out, axis=[2, 3])
scale = out * inputs return scaleclass BasicBlock(nn.Layer):
expansion = 1
def __init__(self,
ch_in,
ch_out,
stride,
shortcut,
variant='b',
groups=1,
base_width=64,
lr=1.0,
norm_type='bn',
norm_decay=0.,
freeze_norm=True,
dcn_v2=False,
std_senet=False):
super(BasicBlock, self).__init__() assert dcn_v2 is False, "Not implemented yet."
assert groups == 1 and base_width == 64, 'BasicBlock only supports groups=1 and base_width=64'
self.shortcut = shortcut if not shortcut: if variant == 'd' and stride == 2:
self.short = nn.Sequential()
self.short.add_sublayer( 'pool',
nn.AvgPool2D(
kernel_size=2, stride=2, padding=0, ceil_mode=True))
self.short.add_sublayer( 'conv',
ConvNormLayer(
ch_in=ch_in,
ch_out=ch_out,
filter_size=1,
stride=1,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr)) else:
self.short = ConvNormLayer(
ch_in=ch_in,
ch_out=ch_out,
filter_size=1,
stride=stride,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr)
self.branch2a = ConvNormLayer(
ch_in=ch_in,
ch_out=ch_out,
filter_size=3,
stride=stride,
act='relu',
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr)
self.branch2b = ConvNormLayer(
ch_in=ch_out,
ch_out=ch_out,
filter_size=3,
stride=1,
act=None,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr)
self.std_senet = std_senet if self.std_senet:
self.se = SELayer(ch_out) def forward(self, inputs):
out = self.branch2a(inputs)
out = self.branch2b(out) if self.std_senet:
out = self.se(out) if self.shortcut:
short = inputs else:
short = self.short(inputs)
out = paddle.add(x=out, y=short)
out = F.relu(out) return outclass BottleNeck(nn.Layer):
expansion = 4
def __init__(self,
x,
y,
z,
ch_in, # 1024
ch_out, #512
stride, #
shortcut,
img_size=(640,640),
variant='b',
groups=1,
base_width=4,
lr=1.0,
norm_type='bn',
norm_decay=0.,
freeze_norm=True,
dcn_v2=False,
std_senet=False):
super(BottleNeck, self).__init__() if variant == 'a':
stride1, stride2 = stride, 1
else:
stride1, stride2 = 1, stride # ResNeXt
width = int(ch_out * (base_width / 64.)) * groups
self.shortcut = shortcut if not shortcut: if variant == 'd' and stride == 2:
self.short = nn.Sequential()
self.short.add_sublayer( 'pool',
nn.AvgPool2D(
kernel_size=2, stride=2, padding=0, ceil_mode=True))
self.short.add_sublayer( 'conv',
ConvNormLayer(
ch_in=ch_in,
ch_out=ch_out * self.expansion,
filter_size=1,
stride=1,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr)) else:
self.short = ConvNormLayer(
ch_in=ch_in,
ch_out=ch_out * self.expansion,
filter_size=1,
stride=stride,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr)
self.branch2a = ConvNormLayer(
ch_in=ch_in,
ch_out=width,
filter_size=1,
stride=stride1,
groups=1,
act='relu',
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr)
if x and y:
self.branch2b = paddle.nn.LayerList()
self.branch2b.append(MHSA(512,[40, 40],4,128,128))
self.branch2b.append(paddle.nn.AvgPool2D(2, 2))
self.branch2b = paddle.nn.Sequential(*self.branch2b) elif x and not y: if z==0 :
self.branch2b = MHSA(512,[20, 20],4,128,128) elif z==1:
self.branch2b = ConvNormLayer(
ch_in=width,
ch_out=width,
filter_size=3,
stride=stride2,
groups=groups,
act='relu',
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr,
dcn_v2=True) else:
self.branch2b = ConvNormLayer(
ch_in=width,
ch_out=width,
filter_size=3,
stride=stride2,
groups=groups,
act='relu',
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr,
dcn_v2=dcn_v2)
self.branch2c = ConvNormLayer(
ch_in=width,
ch_out=ch_out * self.expansion,
filter_size=1,
stride=1,
groups=1,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=lr)
self.std_senet = std_senet if self.std_senet:
self.se = SELayer(ch_out * self.expansion) def forward(self, inputs):
out = self.branch2a(inputs)
out = self.branch2b(out)
out = self.branch2c(ou t) if self.std_senet:
out = self.se(out) if self.shortcut:
short = inputs else:
short = self.short(inputs)
out = paddle.add(x=out, y=short)
out = F.relu(out) return outclass Blocks(nn.Layer):
def __init__(self,
block,
x,
ch_in,
ch_out,
count,
name_adapter,
stage_num,
img_size = (640,640),
variant='b',
groups=1,
base_width=64,
lr=1.0,
norm_type='bn',
norm_decay=0.,
freeze_norm=True,
dcn_v2=False,
std_senet=False):
super(Blocks, self).__init__()
self.blocks = [] for i in range(count): if i == 0:
y = 1
z = 0
else: if i==count-1:
y = 0
z = 1
else:
y = 0
z = 0
conv_name = name_adapter.fix_layer_warp_name(stage_num, count, i)
layer = self.add_sublayer(
conv_name,
block(
x,
y,
z,
ch_in=ch_in,
ch_out=ch_out,
stride=2 if i == 0 and stage_num != 2 else 1,
shortcut=False if i == 0 else True,
img_size=img_size,
variant=variant,
groups=groups,
base_width=base_width,
lr=lr,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
dcn_v2=dcn_v2,
std_senet=std_senet))
self.blocks.append(layer) if i == 0:
ch_in = ch_out * block.expansion def forward(self, inputs):
block_out = inputs for block in self.blocks:
block_out = block(block_out) return block_out@register@serializableclass BotNet(nn.Layer):
__shared__ = ['norm_type'] def __init__(self,
depth=50,
img_size = [20,20],
ch_in=64,
variant='b',
lr_mult_list=[1.0, 1.0, 1.0, 1.0],
groups=1,
base_width=64,
norm_type='bn',
norm_decay=0,
freeze_norm=True,
freeze_at=0,
return_idx=[0, 1, 2, 3],
dcn_v2_stages=[-1], # [3]
num_stages=4,
std_senet=False):
"""
Residual Network, see https://arxiv.org/abs/1512.03385
Args:
depth (int): ResNet depth, should be 18, 34, 50, 101, 152.
ch_in (int): output channel of first stage, default 64
variant (str): ResNet variant, supports 'a', 'b', 'c', 'd' currently
lr_mult_list (list): learning rate ratio of different resnet stages(2,3,4,5),
lower learning rate ratio is need for pretrained model
got using distillation(default as [1.0, 1.0, 1.0, 1.0]).
groups (int): group convolution cardinality
base_width (int): base width of each group convolution
norm_type (str): normalization type, 'bn', 'sync_bn' or 'affine_channel'
norm_decay (float): weight decay for normalization layer weights
freeze_norm (bool): freeze normalization layers
freeze_at (int): freeze the backbone at which stage
return_idx (list): index of the stages whose feature maps are returned
dcn_v2_stages (list): index of stages who select deformable conv v2
num_stages (int): total num of stages
std_senet (bool): whether use senet, default True
"""
super(BotNet, self).__init__()
self._model_type = 'ResNet' if groups == 1 else 'ResNeXt'
assert num_stages >= 1 and num_stages <= 4
self.depth = depth
self.variant = variant
self.groups = groups
self.base_width = base_width
self.norm_type = norm_type
self.norm_decay = norm_decay
self.freeze_norm = freeze_norm
self.freeze_at = freeze_at if isinstance(return_idx, Integral):
return_idx = [return_idx] assert max(return_idx) < num_stages, 'the maximum return index must smaller than num_stages, ' 'but received maximum return index is {} and num_stages ' 'is {}'.format(max(return_idx), num_stages)
self.return_idx = return_idx
self.num_stages = num_stages assert len(lr_mult_list) == 4, "lr_mult_list length must be 4 but got {}".format(len(lr_mult_list)) if isinstance(dcn_v2_stages, Integral):
dcn_v2_stages = [dcn_v2_stages] assert max(dcn_v2_stages) < num_stages if isinstance(dcn_v2_stages, Integral):
dcn_v2_stages = [dcn_v2_stages] assert max(dcn_v2_stages) < num_stages
self.dcn_v2_stages = dcn_v2_stages
block_nums = ResNet_cfg[depth]
na = NameAdapter(self)
conv1_name = na.fix_c1_stage_name() if variant in ['c', 'd']:
conv_def = [
[3, ch_in // 2, 3, 2, "conv1_1"],
[ch_in // 2, ch_in // 2, 3, 1, "conv1_2"],
[ch_in // 2, ch_in, 3, 1, "conv1_3"],
] else:
conv_def = [[1, ch_in, 7, 2, conv1_name]]
self.conv1 = nn.Sequential() for (c_in, c_out, k, s, _name) in conv_def:
self.conv1.add_sublayer(
_name,
ConvNormLayer(
ch_in=c_in,
ch_out=c_out,
filter_size=k,
stride=s,
groups=1,
act='relu',
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=1.0))
self.ch_in = ch_in
ch_out_list = [64, 128, 256, 512]
block = BottleNeck if depth >= 50 else BasicBlock
self._out_channels = [block.expansion * v for v in ch_out_list]
self._out_strides = [4, 8, 16, 32]
self.res_layers = [] for i in range(num_stages): if i == 3 :
x = 1
else :
x = 0
lr_mult = lr_mult_list[i]
stage_num = i + 2
res_name = "res{}".format(stage_num)
res_layer = self.add_sublayer(
res_name,
Blocks(
block,
x,
self.ch_in,
ch_out_list[i],
count=block_nums[i],
name_adapter=na,
stage_num=stage_num,
img_size = img_size,
variant=variant,
groups=groups,
base_width=base_width,
lr=lr_mult,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
dcn_v2=(i in self.dcn_v2_stages),
std_senet=std_senet))
self.res_layers.append(res_layer)
self.ch_in = self._out_channels[i] @property
def out_shape(self):
return [
ShapeSpec(
channels=self._out_channels[i], stride=self._out_strides[i]) for i in self.return_idx
] def forward(self, inputs):
# x = inputs['image'][:,0,:,:]
x = inputs['image'] # x = paddle.unsqueeze(x,axis=1)
conv1 = self.conv1(x)
x = F.max_pool2d(conv1, kernel_size=3, stride=2, padding=1)
outs = [] for idx, stage in enumerate(self.res_layers):
x = stage(x) if idx == self.freeze_at:
x.stop_gradient = True
if idx in self.return_idx:
outs.append(x) return outs@registerclass Bot5Head(nn.Layer):
def __init__(self, depth=50):
super(Bot5Head, self).__init__()
feat_in, feat_out = [1024, 512] if depth < 50:
feat_in = 256
na = NameAdapter(self)
block = BottleNeck if depth >= 50 else BasicBlock
self.res5 = Blocks(""
block, feat_in, feat_out, count=3, name_adapter=na, stage_num=5)
self.feat_out = feat_out if depth < 50 else feat_out * 4 @property
def out_shape(self):
return [ShapeSpec(
channels=self.feat_out,
stride=16, )] def forward(self, roi_feat, stage=0):
y = self.res5(roi_feat) return y
import paddleimport paddle.nn as nnimport paddle.nn.functional as Ffrom paddle import ParamAttrfrom paddle.regularizer import L2Decayfrom ppdet.core.workspace import registerdef _de_sigmoid(x, eps=1e-7):
    x = paddle.clip(x, eps, 1. / eps)
    x = paddle.clip(1. / x - 1., eps, 1. / eps)
    x = -paddle.log(x)    return xclass SiLU(nn.Layer):    @staticmethod
    def forward(x):
        return x * F.sigmoid(x)def mish(x):
    return x * paddle.tanh(F.softplus(x))class BaseConv(nn.Layer):
    def __init__(self, in_channels, out_channels, ksize, stride, groups=1, bias=False, act="silu"):
        super().__init__()
        pad = (ksize - 1) // 2
        self.conv = nn.Conv2D(in_channels, out_channels, kernel_size=ksize,
                              stride=stride, padding=pad, groups=groups, bias_attr=bias)
        self.bn = nn.SyncBatchNorm(
            out_channels)
        self.act = mish    def forward(self, x):
        return self.act(self.bn(self.conv(x)))class DWConv(nn.Layer):
    def __init__(self, in_channels, out_channels, ksize, stride=1, act="silu"):
        super().__init__()
        self.dconv = BaseConv(in_channels, in_channels, ksize=ksize,
                              stride=stride, groups=in_channels, act=act,)
        self.pconv = BaseConv(in_channels, out_channels,
                              ksize=1, stride=1, groups=1, act=act)    def forward(self, x):
        x = self.dconv(x)        return self.pconv(x)# def _de_sigmoid(x, eps=1e-7):#     x = paddle.clip(x, eps, 1. / eps)#     x = paddle.clip(1. / x - 1., eps, 1. / eps)#     x = -paddle.log(x)#     return x@registerclass YOLOvXHead(nn.Layer):
    __shared__ = ['num_classes', 'data_format']
    __inject__ = ['loss']    def __init__(self,
                 in_channels=[1024, 512, 256],
                 anchors=[[10, 13], [16, 30], [33, 23], [30, 61], [62, 45],
                          [59, 119], [116, 90], [156, 198], [373, 326]],
                 anchor_masks=[[6, 7, 8], [3, 4, 5], [0, 1, 2]],
                 num_classes=80,
                 loss='YOLOv3Loss',
                 iou_aware=False,
                 iou_aware_factor=0.4,
                 data_format='NCHW'):
        """
        Head for YOLOv3 network

        Args:
            num_classes (int): number of foreground classes
            anchors (list): anchors
            anchor_masks (list): anchor masks
            loss (object): YOLOv3Loss instance
            iou_aware (bool): whether to use iou_aware
            iou_aware_factor (float): iou aware factor
            data_format (str): data format, NCHW or NHWC
        """
        super(YOLOvXHead, self).__init__()        assert len(in_channels) > 0, "in_channels length should > 0"
        self.in_channels = in_channels
        self.num_classes = num_classes
        self.loss = loss

        self.iou_aware = iou_aware
        self.iou_aware_factor = iou_aware_factor

        self.parse_anchor(anchors, anchor_masks)
        self.num_outputs = len(self.anchors)
        self.data_format = data_format

        self.yolo_outputs = []
        self.stems = nn.LayerList()
        self.cls_convs = nn.LayerList()
        self.reg_convs = nn.LayerList()
        self.cls_preds = nn.LayerList()
        self.reg_preds = nn.LayerList()
        self.obj_preds = nn.LayerList()        #self.iou        = nn.LayerList()
        act = 'RELU'
        for i in range(len(self.anchors)):            if self.iou_aware:
                num_filters = len(self.anchors[i]) * (self.num_classes + 6)            else:
                num_filters = len(self.anchors[i]) * (self.num_classes + 5)

            self.stems.append(BaseConv(in_channels=int(
                in_channels[i]), out_channels=int(in_channels[i]), ksize=1, stride=1, act=act))
            self.cls_convs.append(nn.Sequential(*[
                BaseConv(in_channels=int(in_channels[i]), out_channels=int(
                    in_channels[i]), ksize=3, stride=1, act=act),
                BaseConv(in_channels=int(in_channels[i]), out_channels=int(
                    in_channels[i]), ksize=3, stride=1, act=act)
            ]))
            self.cls_preds.append(
                nn.Conv2D(in_channels=int(in_channels[i]), out_channels=(                    1+self.num_classes)*3, kernel_size=1, stride=1, padding=0)
            )

            self.reg_convs.append(nn.Sequential(*[
                BaseConv(in_channels=int(in_channels[i]), out_channels=int(
                    in_channels[i]), ksize=3, stride=1, act=act),
                BaseConv(in_channels=int(in_channels[i]), out_channels=int(
                    in_channels[i]), ksize=3, stride=1, act=act)
            ]))
            self.reg_preds.append(
                nn.Conv2D(in_channels=int(in_channels[i]), out_channels=4 *                          3, kernel_size=1, stride=1, padding=0)
            )            if self.iou_aware:
                self.obj_preds.append(
                    nn.Conv2D(in_channels=int(in_channels[i]), out_channels=1 *                              3, kernel_size=1, stride=1, padding=0)
                )
            name = 'yolo_output.{}'.format(i)
            conv = nn.Conv2D(
                in_channels=self.in_channels[i],
                out_channels=num_filters,
                kernel_size=1,
                stride=1,
                padding=0,
                data_format=data_format,
                bias_attr=ParamAttr(regularizer=L2Decay(0.)))
            conv.skip_quant = True
            yolo_output = self.add_sublayer(name, conv)
            self.yolo_outputs.append(yolo_output)    def parse_anchor(self, anchors, anchor_masks):
        self.anchors = [[anchors[i] for i in mask] for mask in anchor_masks]
        self.mask_anchors = []
        anchor_num = len(anchors)        for masks in anchor_masks:
            self.mask_anchors.append([])            for mask in masks:                assert mask < anchor_num, "anchor mask index overflow"
                self.mask_anchors[-1].extend(anchors[mask])    def forward(self, feats, targets=None):
        #-------------------------------------#
        #   feats 三层特征图
        #-------------------------------------#
        #-------------------------------------#
        #   targets
        #   im_id
        #   is_crowd
        #   gt_bbox
        #   curr_iter
        #   image
        #   im_shape
        #   scale_factor
        #   target0
        #   target1
        #   target2
        #-------------------------------------#
        assert len(feats) == len(self.anchors)
        yolo_outputs = []        for i, feat in enumerate(feats):            #---------------------------------------------------#
            #   利用1x1卷积进行通道整合
            #---------------------------------------------------#
            x = self.stems[i](feat)            #---------------------------------------------------#
            #   利用两个卷积标准化激活函数来进行特征提取
            #---------------------------------------------------#
            cls_feat = self.cls_convs[i](x)            #---------------------------------------------------#
            #   判断特征点所属的种类
            #   80, 80, num_classes
            #   40, 40, num_classes
            #   20, 20, num_classes
            #---------------------------------------------------#
            cls_output = self.cls_preds[i](cls_feat)            #---------------------------------------------------#
            #   利用两个卷积标准化激活函数来进行特征提取
            #---------------------------------------------------#
            reg_feat = self.reg_convs[i](x)            #---------------------------------------------------#
            #   特征点的回归系数
            #   reg_pred 80, 80, 4
            #   reg_pred 40, 40, 4
            #   reg_pred 20, 20, 4
            #---------------------------------------------------#
            reg_output = self.reg_preds[i](reg_feat)            #---------------------------------------------------#
            #   判断特征点是否有对应的物体
            #   obj_pred 80, 80, 1
            #   obj_pred 40, 40, 1
            #   obj_pred 20, 20, 1
            #---------------------------------------------------#
            if self.iou_aware:
                obj_output = self.obj_preds[i](reg_feat)            if self.iou_aware:
                output = paddle.concat([obj_output, reg_output, cls_output], 1)            else:
                output = paddle.concat([reg_output, cls_output], 1)

            yolo_outputs.append(output)        if self.training:            return self.loss(yolo_outputs, targets, self.anchors)        else:            if self.iou_aware:
                y = []                for i, out in enumerate(yolo_outputs):
                    na = len(self.anchors[i])
                    ioup, x = out[:, 0:na, :, :], out[:, na:, :, :]
                    b, c, h, w = x.shape
                    no = c // na
                    x = x.reshape((b, na, no, h * w))
                    ioup = ioup.reshape((b, na, 1, h * w))
                    obj = x[:, :, 4:5, :]
                    ioup = F.sigmoid(ioup)
                    obj = F.sigmoid(obj)
                    obj_t = (obj**(1 - self.iou_aware_factor)) * (
                        ioup**self.iou_aware_factor)
                    obj_t = _de_sigmoid(obj_t)
                    loc_t = x[:, :, :4, :]
                    cls_t = x[:, :, 5:, :]
                    y_t = paddle.concat([loc_t, obj_t, cls_t], axis=2)
                    y_t = y_t.reshape((b, c, h, w))
                    y.append(y_t)                return y            else:                return yolo_outputs    @classmethod
    def from_config(cls, cfg, input_shape):
        return {'in_channels': [i.channels for i in input_shape], }
以上就是【创造营第二期】水下声呐探测,带你揭开海底的真实面纱的详细内容,更多请关注其它相关文章!
# git
# 韶关网站推广推荐
# 杭州网站优化服务
# 是在
# 这是因为
# 是由
# 一言
# 第二期
# 的是
# 带你
# 中文网
# 海底
# 飞桨paddlep
# python
# apache
# 谷歌
# 工具
# ai
# 百度
# 区别
# overflow
# red
# asic
# 水下
# 长寿的网站建设高端团队
# 廊坊网站建设的策划方案
# 饰品品牌关键词优化排名
# seo复盘工具
# seo实验过程和原理
# 羽毛seo博客
# 沈阳网站建设商城
# 绥化seo技巧如何引流
相关栏目:
【
Google疑问12 】
【
Facebook疑问10 】
【
优化推广96088 】
【
技术知识133117 】
【
IDC资讯59369 】
【
网络运营7196 】
【
IT资讯61894 】
相关推荐:
Meta推出VR订阅服务Quest +:每月免费玩两款游戏,7.99美元/月
掌阅科技对话式AI应用“阅爱聊”开启内测
机器人技能大比拼
田渊栋团队新研究:微调
新华全媒+|AI:当心,我可能欺骗了你!
鸿蒙生态带来了哪些新的流量可能性,包括AI、服务分发和原生智能等方面?
280万条多模态指令-响应对,八种语言通用,首个涵盖视频内容的指令数据集MIMIC-IT来了
AI赋能艺术 超现实达利奇幻之旅在沪开启
AI成政客博弈工具,美国大选真假难辨,律师们的生意来了
刊·见 | 捕捉人工智能领域最新动态?收藏Applied Artificial Intelligence
谷歌推出RT-2视觉语言动作模型,使机器人能够掌握垃圾丢弃技能
企业软件行业更将被AI全面重构!Moka李国兴:未来优秀组织和个人将一定是善于使用AI生产力的
网易数帆以AI融合创新引领数据分析与软件开发新趋势
苹果CEO库克:持续研究生成式人工智能技术
微软推出人工智能模型 CoDi,可互动和生成多模态内容
彭博社:苹果Vision Pro曾测试VR手柄追踪方案
精准度可提高 20%:英国九家银行签约使用基于 AI 的“消费者欺诈风险系统”应对*
硅谷人工智能研究院创始人皮埃罗·斯加鲁菲:Transformer模型演讲
元宇宙技术带你穿梭“大运河”,江苏书展上的数字阅读馆吸睛小读者
Midjourney创始人:AI应该成为人类思想的延伸
国内阅读行业首款对话式AI应用“阅爱聊”封闭内测
美图公司影像节或发布AI设计新品
五款 AI 网站构建器,任何人都能快速构建网站
Dubbo负载均衡策略之 一致性哈希
这效果能打几分?AI真人化《名侦探柯南》
微软大牛加入ZOOM,AI人才大战打响
2025 年开发者必须知道的六个 AI 工具
用人工智能技术,亚马逊为用户生成产品评论摘要,帮助他们轻松选购
AI+音乐如何“生成”动听旋律?一起揭秘世界人工智能大会开场曲
微软在德国举办MR研讨会,向女性分享元宇宙潜力
微软宣布为 Azure AI 添加男性声线,增强文本转语音功能
XREAL发布新款硬件XREAL Beam投屏盒子:可悬停AR空间屏
GPT-4成功战胜AI-Guardian审核系统:谷歌研究团队的人工智能抵抗人工智能
大脚攀爬者车主福利!无人机、运动相机大奖等你来挑战
广州团建公司方案 | 绝密飞行 → X-PLANE无人机团建主题团建
吉林首例!机器人辅助下搭桥手术成功实施
Nature发AIGC禁令!投稿中视觉内容使用AI的概不接收
AI拉动PCB发展|行业发现
GPT-4使用混合大模型?研究证明MoE+指令调优确实让大模型性能超群
借助ChatGPT快速上手ElasticSearch dsl
RoboNeo操作教程
农业产业升级:AI驱动的“崃·见田”开启农田未来展望
实现人工智能和物联网的协同运作
国内AI大模型“安卓时刻”到来!阿里云通义千问免费、开源、可商用
人形机器人打开精密齿轮市场全新空间!受益上市公司梳理
字节、网易相继入局,AI之后大厂又找到下一个风口?
科技有狠活|时光修复师 :用AI让昨日重现
iPhone两秒出图,目前已知的最快移动端Stable Diffusion模型来了
从医疗康复外骨骼到通用人形机器人,傅利叶智能推动核心技术升级
AI新风口?首个高质量「文生视频」模型Zeroscope引发开源大战:最低8G显存可跑
2025-08-01

运城市盐湖区信雨科技有限公司是一家深耕海外推广领域十年的专业服务商,作为谷歌推广与Facebook广告全球合作伙伴,聚焦外贸企业出海痛点,以数字化营销为核心,提供一站式海外营销解决方案。公司凭借十年行业沉淀与平台官方资源加持,打破传统外贸获客壁垒,助力企业高效开拓全球市场,成为中小企业出海的可靠合作伙伴。

 t) if self.std_senet:
out = self.se(out) if self.shortcut:
short = inputs else:
short = self.short(inputs)
out = paddle.add(x=out, y=short)
out = F.relu(out) return outclass Blocks(nn.Layer):
def __init__(self,
block,
x,
ch_in,
ch_out,
count,
name_adapter,
stage_num,
img_size = (640,640),
variant='b',
groups=1,
base_width=64,
lr=1.0,
norm_type='bn',
norm_decay=0.,
freeze_norm=True,
dcn_v2=False,
std_senet=False):
super(Blocks, self).__init__()
self.blocks = [] for i in range(count): if i == 0:
y = 1
z = 0
else: if i==count-1:
y = 0
z = 1
else:
y = 0
z = 0
conv_name = name_adapter.fix_layer_warp_name(stage_num, count, i)
layer = self.add_sublayer(
conv_name,
block(
x,
y,
z,
ch_in=ch_in,
ch_out=ch_out,
stride=2 if i == 0 and stage_num != 2 else 1,
shortcut=False if i == 0 else True,
img_size=img_size,
variant=variant,
groups=groups,
base_width=base_width,
lr=lr,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
dcn_v2=dcn_v2,
std_senet=std_senet))
self.blocks.append(layer) if i == 0:
ch_in = ch_out * block.expansion def forward(self, inputs):
block_out = inputs for block in self.blocks:
block_out = block(block_out) return block_out@register@serializableclass BotNet(nn.Layer):
__shared__ = ['norm_type'] def __init__(self,
depth=50,
img_size = [20,20],
ch_in=64,
variant='b',
lr_mult_list=[1.0, 1.0, 1.0, 1.0],
groups=1,
base_width=64,
norm_type='bn',
norm_decay=0,
freeze_norm=True,
freeze_at=0,
return_idx=[0, 1, 2, 3],
dcn_v2_stages=[-1], # [3]
num_stages=4,
std_senet=False):
"""
Residual Network, see https://arxiv.org/abs/1512.03385
Args:
depth (int): ResNet depth, should be 18, 34, 50, 101, 152.
ch_in (int): output channel of first stage, default 64
variant (str): ResNet variant, supports 'a', 'b', 'c', 'd' currently
lr_mult_list (list): learning rate ratio of different resnet stages(2,3,4,5),
lower learning rate ratio is need for pretrained model
got using distillation(default as [1.0, 1.0, 1.0, 1.0]).
groups (int): group convolution cardinality
base_width (int): base width of each group convolution
norm_type (str): normalization type, 'bn', 'sync_bn' or 'affine_channel'
norm_decay (float): weight decay for normalization layer weights
freeze_norm (bool): freeze normalization layers
freeze_at (int): freeze the backbone at which stage
return_idx (list): index of the stages whose feature maps are returned
dcn_v2_stages (list): index of stages who select deformable conv v2
num_stages (int): total num of stages
std_senet (bool): whether use senet, default True
"""
super(BotNet, self).__init__()
self._model_type = 'ResNet' if groups == 1 else 'ResNeXt'
assert num_stages >= 1 and num_stages <= 4
self.depth = depth
self.variant = variant
self.groups = groups
self.base_width = base_width
self.norm_type = norm_type
self.norm_decay = norm_decay
self.freeze_norm = freeze_norm
self.freeze_at = freeze_at if isinstance(return_idx, Integral):
return_idx = [return_idx] assert max(return_idx) < num_stages, 'the maximum return index must smaller than num_stages, ' 'but received maximum return index is {} and num_stages ' 'is {}'.format(max(return_idx), num_stages)
self.return_idx = return_idx
self.num_stages = num_stages assert len(lr_mult_list) == 4, "lr_mult_list length must be 4 but got {}".format(len(lr_mult_list)) if isinstance(dcn_v2_stages, Integral):
dcn_v2_stages = [dcn_v2_stages] assert max(dcn_v2_stages) < num_stages if isinstance(dcn_v2_stages, Integral):
dcn_v2_stages = [dcn_v2_stages] assert max(dcn_v2_stages) < num_stages
self.dcn_v2_stages = dcn_v2_stages
block_nums = ResNet_cfg[depth]
na = NameAdapter(self)
conv1_name = na.fix_c1_stage_name() if variant in ['c', 'd']:
conv_def = [
[3, ch_in // 2, 3, 2, "conv1_1"],
[ch_in // 2, ch_in // 2, 3, 1, "conv1_2"],
[ch_in // 2, ch_in, 3, 1, "conv1_3"],
] else:
conv_def = [[1, ch_in, 7, 2, conv1_name]]
self.conv1 = nn.Sequential() for (c_in, c_out, k, s, _name) in conv_def:
self.conv1.add_sublayer(
_name,
ConvNormLayer(
ch_in=c_in,
ch_out=c_out,
filter_size=k,
stride=s,
groups=1,
act='relu',
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
lr=1.0))
self.ch_in = ch_in
ch_out_list = [64, 128, 256, 512]
block = BottleNeck if depth >= 50 else BasicBlock
self._out_channels = [block.expansion * v for v in ch_out_list]
self._out_strides = [4, 8, 16, 32]
self.res_layers = [] for i in range(num_stages): if i == 3 :
x = 1
else :
x = 0
lr_mult = lr_mult_list[i]
stage_num = i + 2
res_name = "res{}".format(stage_num)
res_layer = self.add_sublayer(
res_name,
Blocks(
block,
x,
self.ch_in,
ch_out_list[i],
count=block_nums[i],
name_adapter=na,
stage_num=stage_num,
img_size = img_size,
variant=variant,
groups=groups,
base_width=base_width,
lr=lr_mult,
norm_type=norm_type,
norm_decay=norm_decay,
freeze_norm=freeze_norm,
dcn_v2=(i in self.dcn_v2_stages),
std_senet=std_senet))
self.res_layers.append(res_layer)
self.ch_in = self._out_channels[i] @property
def out_shape(self):
return [
ShapeSpec(
channels=self._out_channels[i], stride=self._out_strides[i]) for i in self.return_idx
] def forward(self, inputs):
# x = inputs['image'][:,0,:,:]
x = inputs['image'] # x = paddle.unsqueeze(x,axis=1)
conv1 = self.conv1(x)
x = F.max_pool2d(conv1, kernel_size=3, stride=2, padding=1)
outs = [] for idx, stage in enumerate(self.res_layers):
x = stage(x) if idx == self.freeze_at:
x.stop_gradient = True
if idx in self.return_idx:
outs.append(x) return outs@registerclass Bot5Head(nn.Layer):
def __init__(self, depth=50):
super(Bot5Head, self).__init__()
feat_in, feat_out = [1024, 512] if depth < 50:
feat_in = 256
na = NameAdapter(self)
block = BottleNeck if depth >= 50 else BasicBlock
self.res5 = Blocks(""
block, feat_in, feat_out, count=3, name_adapter=na, stage_num=5)
self.feat_out = feat_out if depth < 50 else feat_out * 4 @property
def out_shape(self):
return [ShapeSpec(
channels=self.feat_out,
stride=16, )] def forward(self, roi_feat, stage=0):
y = self.res5(roi_feat) return y